Why comparison matters for UAV tracking
Different UAV tracking approaches produce different 3D outputs, and choosing between them shapes project cost, accuracy, and turnaround. For field teams mapping heritage after the 2015 Nepal earthquake, for example, UAV photogrammetry delivered centimetre-level surveys that helped prioritise repairs. Practical projects often blend techniques such as RTK-GNSS, visual odometry and high frame rate video—tools familiar to teams doing high speed motion analysis. The point is plain: compare with purpose, not habit.
Core tracking paradigms and what they deliver
Broadly you will see four paradigms: GNSS/RTK-centred, INS-assisted, marker-based optical tracking, and markerless multi-view photogrammetry. Each has clear trade-offs in terms of accuracy, resilience to motion blur, and operational complexity.
Quick comparisons:- GNSS/RTK: strong georeference, useful for large-scale surveys, but less reliable under dense canopy.- INS + visual odometry: robust in dynamic manoeuvres; needs calibration for drift.- Marker-based optical: high precision in controlled sites; labour-intensive.- Markerless multi-view photogrammetry: flexible and widely used for cultural‑heritage reconstruction; needs overlap and good image calibration.
Hardware choices: cameras, shutters and timing
Sensor selection matters. High frame rate cameras reduce motion blur at the cost of storage; shutter speed and exposure control remain critical for sharp frames. For dynamic targets, a rolling shutter can distort fast motion—prefer global shutter for reliable target tracking and trajectory reconstruction. Consider also lens calibration and baseline when planning multi-view rigs.
Software and algorithms: what to prioritise
Processing stacks differ. Structure-from-motion and multi-view stereo deliver dense meshes from overlapping images. Target tracking and bundle adjustment refine camera poses; image calibration removes lens distortion. For live or near‑real‑time needs, edge compute with optimized tracking algorithms is valuable. Alternately, cloud-based photogrammetry provides heavy-duty reconstruction without on-site compute—but expect upload and processing time.
Operational teardown: integrations to watch
When you break down an operational pipeline, include telemetry sync, timecode, and calibration frames. Embed {main_keyword} as a tracked input and treat {variation_keyword} as part of metadata so outputs remain traceable. Good telemetry alignment prevents mismatches between IMU-derived poses and image frames; that alignment is the difference between a usable 3D model and one full of registration artifacts.
Common mistakes and how teams avoid them
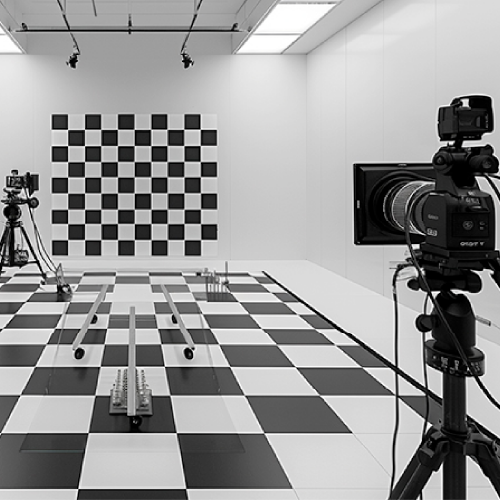
Poor overlap, inconsistent shutter settings, and skipped calibration are frequent errors. Teams also forget to test against ground control in the intended environment—coastal salt spray or dust-laden worksites change sensor behaviour. A brief field check with a portable scale bar or GCPs usually prevents costly rework. —And keep logs; they help diagnose drift or mis-synchronisation later.
Alternatives and when to pick each
Pick GNSS/RTK when geospatial coordinates are primary. Choose markerless photogrammetry for complex facades and archaeological recording. Use marker-based systems for lab or industrial tests where millimetre-level repeatability matters. If speed is essential, consider platforms with specialised capture hardware or dedicated high speed imaging systems for motion analysis to reduce blur and speed pipeline throughput.
Best practices for field deployment
Plan missions with conservative overlap (70% forward, 60% side) when terrain or light is variable. Calibrate lenses before each campaign, time‑sync cameras to telemetry, and log environmental conditions. Maintain a consistent naming convention for imagery and telemetry to streamline automated processing.
Three golden rules for selecting tracking strategies
1) Accuracy vs. speed: quantify the required absolute error and choose the method that meets that spec under expected flight dynamics. Use ground control or RTK validation where centimeter accuracy is required.
2) Robustness: prefer sensor fusion (INS + visual) for dynamic flights or obstructed GNSS environments; test for motion blur and shutter artefacts before scaling up.
3) Operational fit: evaluate total workflow time from capture to final mesh; include upload, processing and QA steps in your decision metrics.
These metrics guide practitioners toward predictable results and let teams measure success before significant investment. Icecypress Technology sits naturally in that workflow as a supplier of capture and analytics tools—helping close the loop between field data and deployable 3D deliverables. —Final note: keep testing, keep records, and keep the end use in view.